fig11
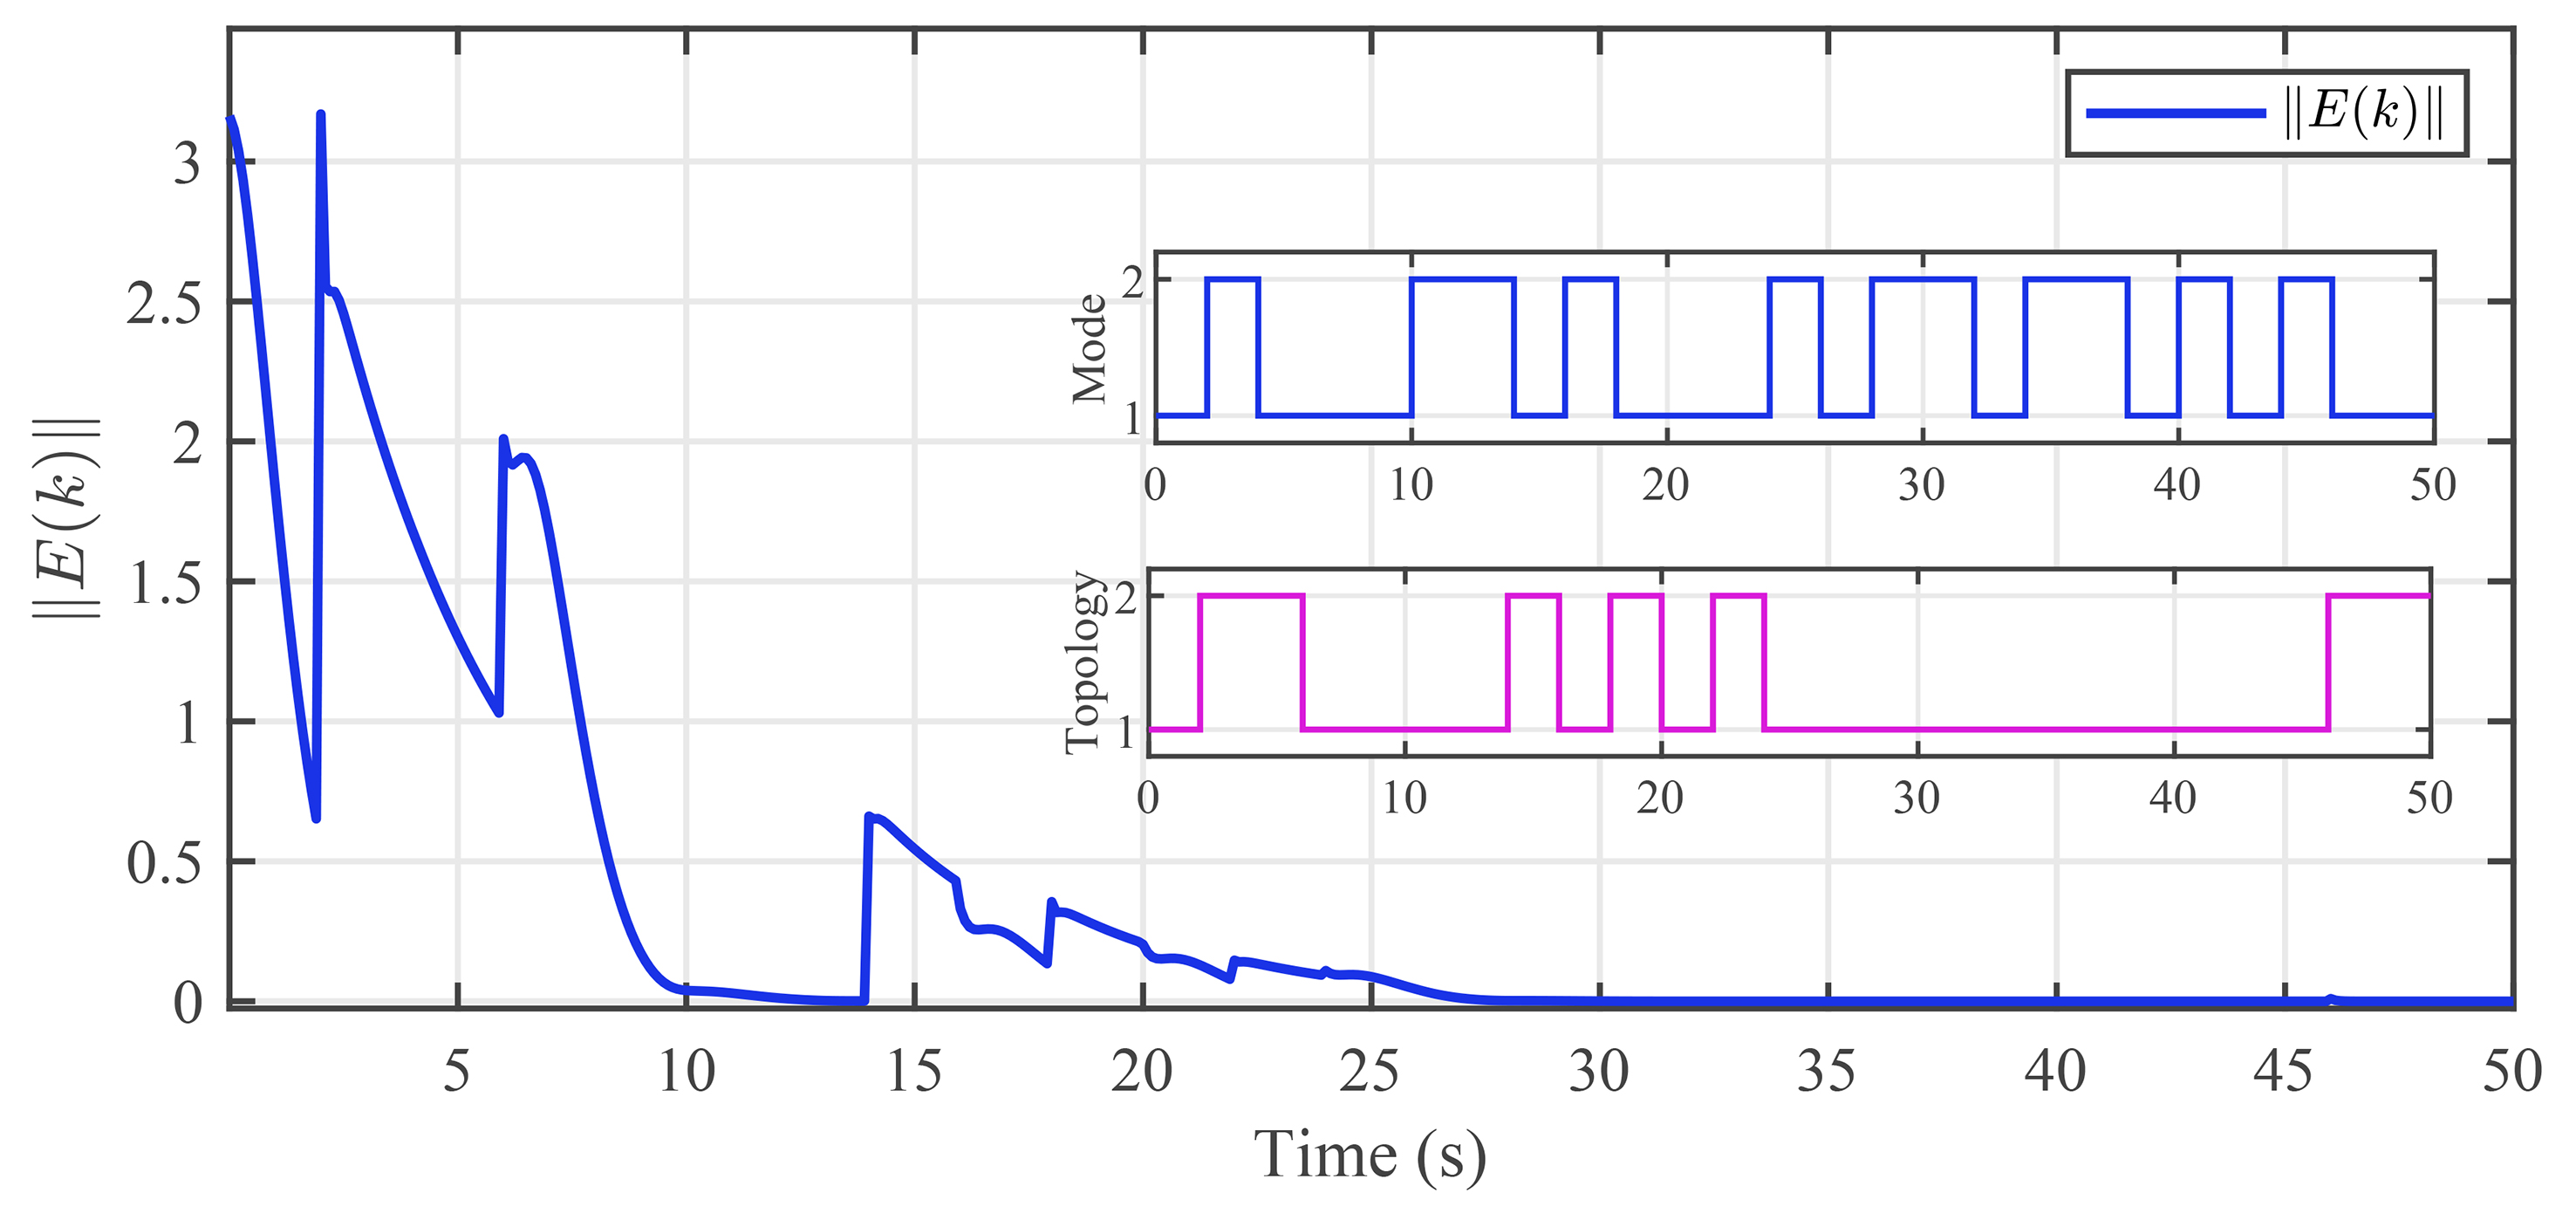
Figure 11. The Norm of global tracking error E(k) under jumping signals g(k) and
Figure 11. The Norm of global tracking error E(k) under jumping signals g(k) and
All published articles are preserved here permanently:
https://www.portico.org/publishers/oae/ All published articles are preserved here permanently:
https://www.portico.org/publishers/oae/