fig8
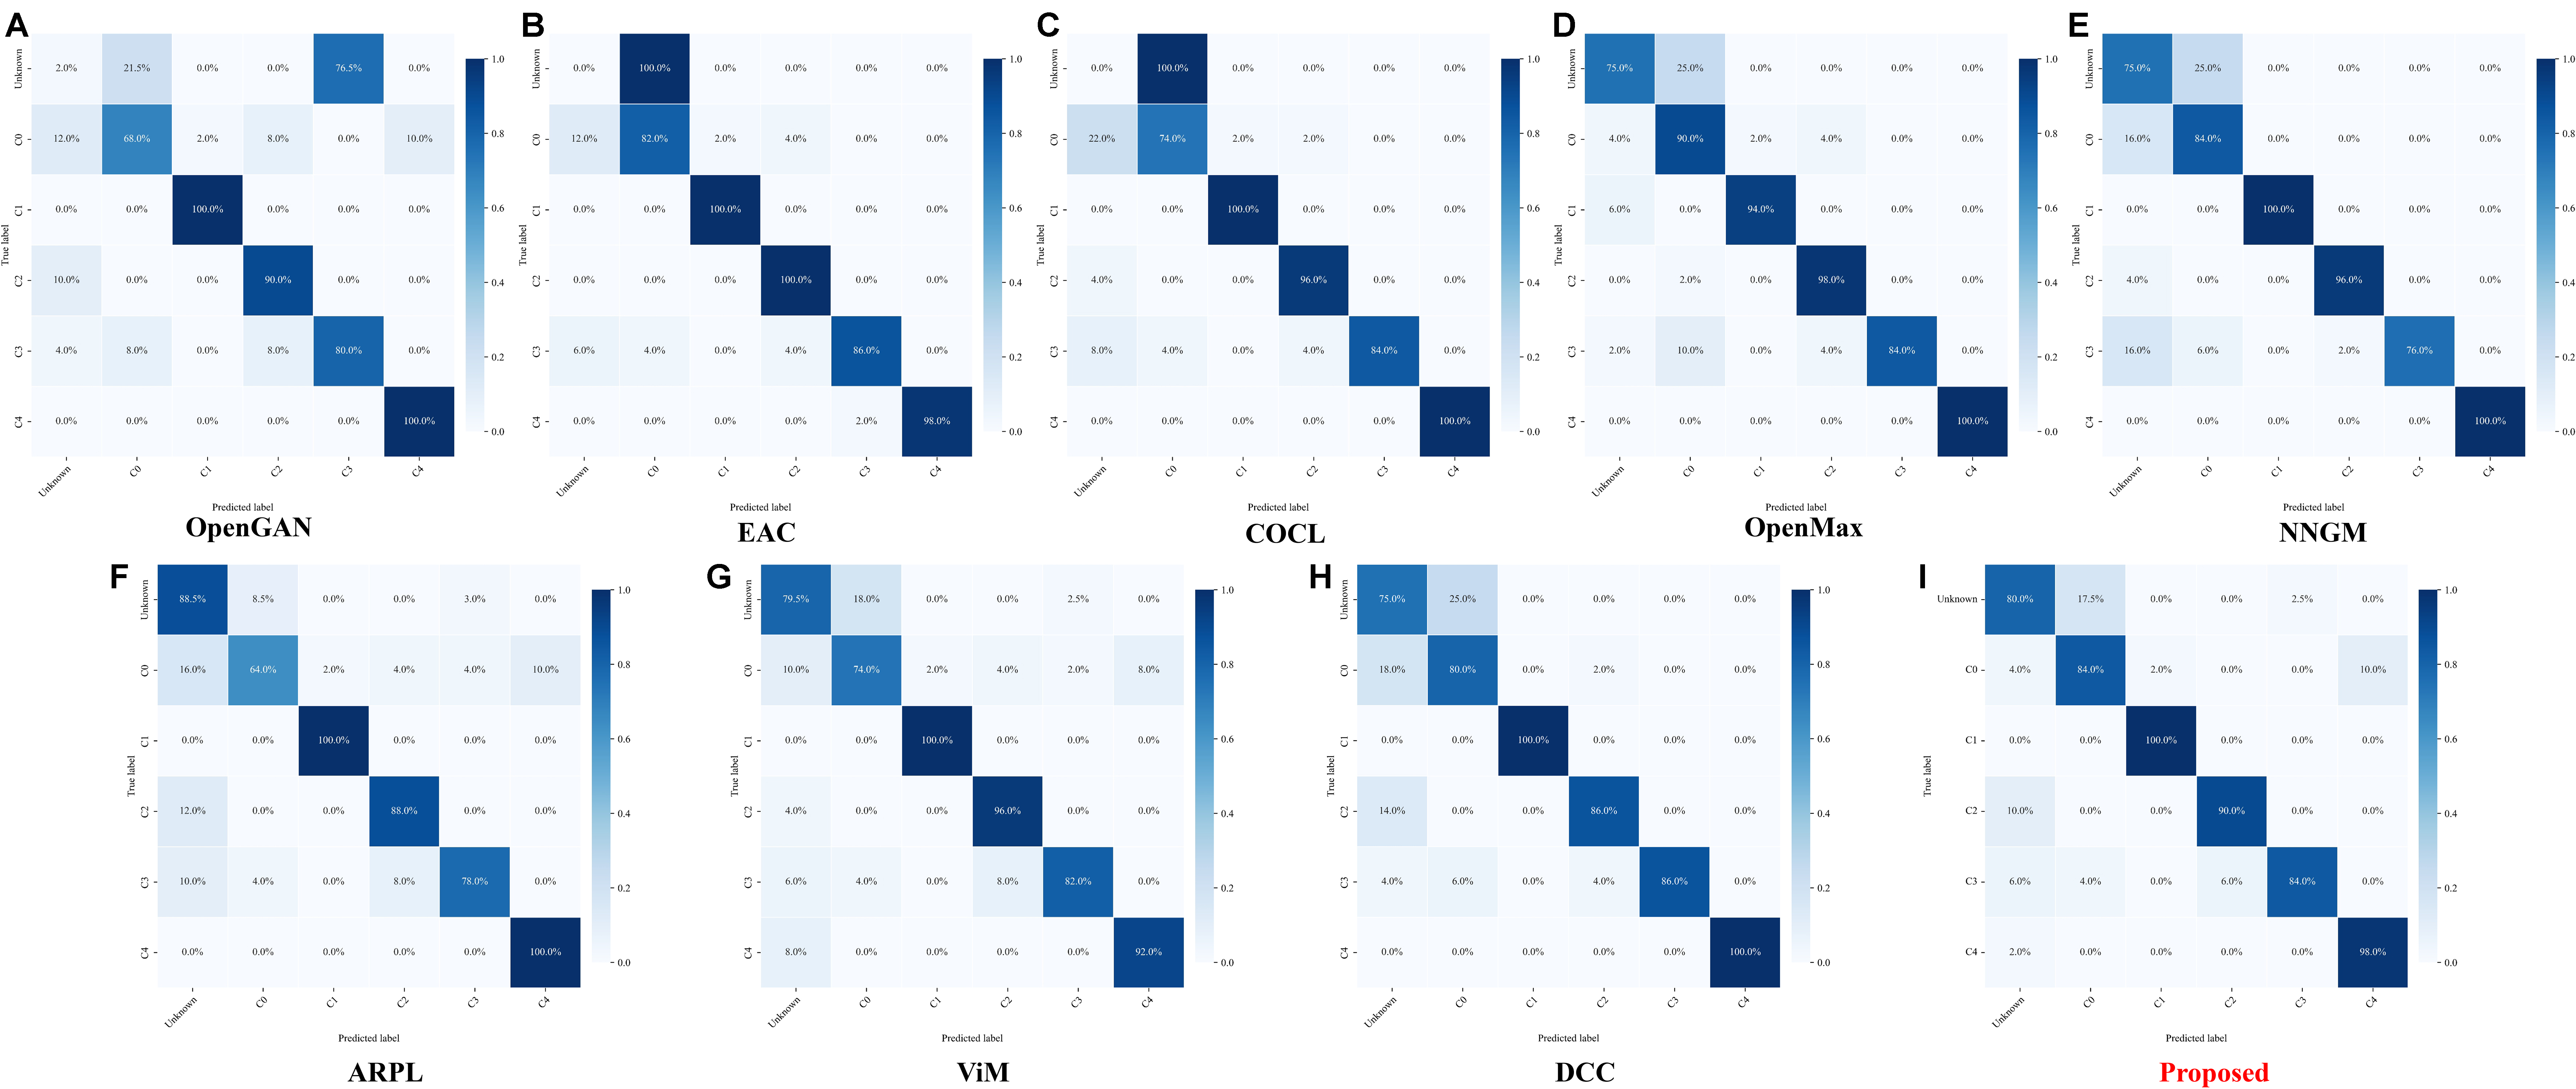
Figure 8. Confusion matrices under a representative challenging open-set task. The representative task corresponds to Task 5 in Table 3; the known classes C0, C2, C3, C4, and C8 are displayed using task-local labels C0-C4, while the unknown class combines C1, C5, C6, and C7. The proposed method exhibits the clearest diagonal structure and the strongest unknown-class recognition, indicating improved separation between known and unknown samples.